Typically, control devices are pre-programmed for specific tasks, but modern exoskeletons are becoming increasingly adaptable. Some are equipped with algorithms that learn from users’ actual work behavior to better support their actions.
However, the support that exoskeletons provide generally falls into three categories.
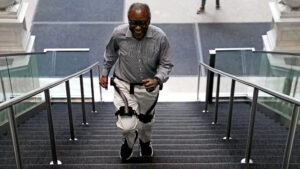
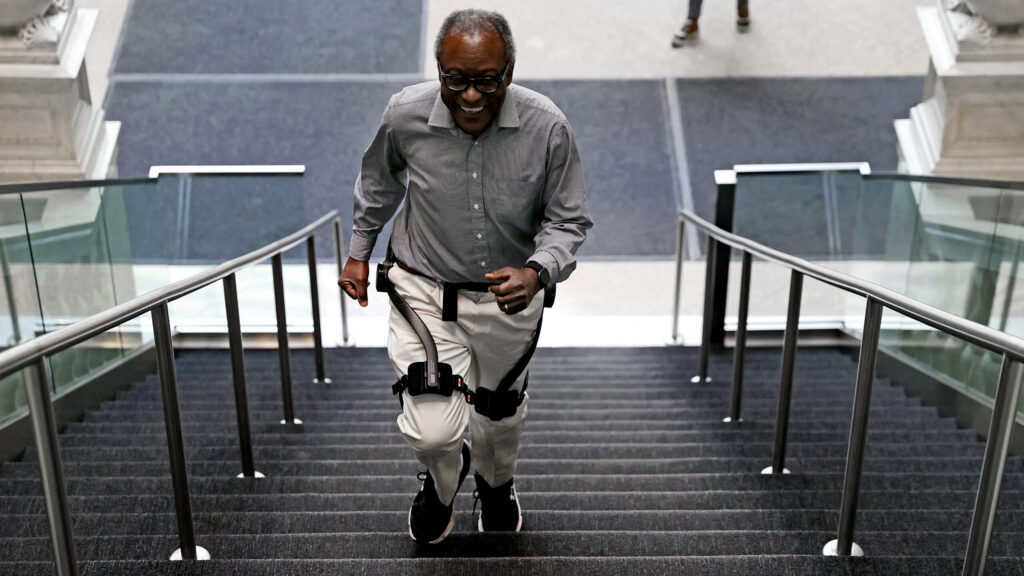
Strength Enhancement increases the user’s strength abilities. This is often seen with supportive exoskeletons, such as those used by IKEA and in Ukraine.
The “Support when needed” or “Resistance when needed” settings only support the body when it is needed. This setting is often used in rehabilitation equipment to help users train their body to restore lost abilities.
Finally there is full robot control, where the exoskeleton takes complete control of a part of the body. This typically applies to users who have lost certain motor functions. For example, a lower body exoskeleton could use full robotic control to enable someone with a spinal cord injury to walk.
These working methods can be combined and adapted depending on the task, environment and needs of the user.
What’s next?
Currently, most exoskeletons rely on feedback from sensors to define how exoskeletons behave. they are completely mechanical. But in the future, exoskeletons could be operated using signals from the wearer’s muscles or brain. Research is investigating this, but it remains a challenge. Exploitation of these signals may require an invasive interface and extensive custom calibration and adjustment.
Another current challenge is power. Batteries must be integrated into exoskeletons and charged regularly. This introduces weight and size restrictions that impact practicality. However, the energy density of batteries is constantly improving.
New materials are also pushing the limits of what is possible. Exoskeletons are being developed that are made of soft textile or rubber-like materials and can be integrated into clothing, shoes or protective equipment.
Research on walking exoskeletons in the 1960s and 1970s contributed to the development of the first humanoid bipedal robots. This brings us full circle. Interest in humanoid robotics is now accelerating the development of actuators and batteries. These will drive the wearable robotic technologies of tomorrow.
Ildar Farkhatdinov, Lecturer in Health Engineering (Robotics and Mechatronics), King’s College London. This article is republished from The Conversation under a Creative Commons license. Read the original article.